-
- Products
- Indoor Household Cords
- Appliance Cords
- General Purpose Short-Length Cords
- General Purpose Extension Cords
- Landscape & Decorating Cords
- Bright Color Extension Cords
- Oil-Resistant Extension Cords
- Cold-Flex Extension Cords
- VividFlex Power Cords
- EXTREME All-Weather Cords
- Cord Management
- Task Lights
- Adapters & GFCI Devices
- Where to Buy
- About
- Careers
- Glossary
- Catalog

How to Choose the Best Optical Sorting Systems?
Choosing the best Optical Sorting Systems starts with a clear view of your material, not a brochure. What are you sorting, and what counts as an acceptable result? A camera may detect color differences well, while another sensor may better identify shape, size, or composition. The right choice depends on the product, contamination levels, line speed, and the cost of missed or incorrect sorting.
Look closely at real samples. Dust, glare, overlapping pieces, and uneven lighting can change results on a busy line. Small details matter. Ask suppliers to run representative material through the equipment, then review accuracy, throughput, and reject rates together. Check whether operators can adjust settings easily and whether cleaning or maintenance interrupts production. Ask how performance is measured; a single headline accuracy figure may not describe everyday operation.
Specifications are useful, but they can look cleaner than real production. A test with a small, carefully prepared sample may not reflect a difficult shift. That deserves a second look. Compare systems under similar conditions, and record what each one detects, misses, or rejects unnecessarily. This guide examines the practical criteria behind a sound decision, from sensor technology and software to integration, service, and long-term operating costs. There is no universal best machine—only a better fit for your material and process.
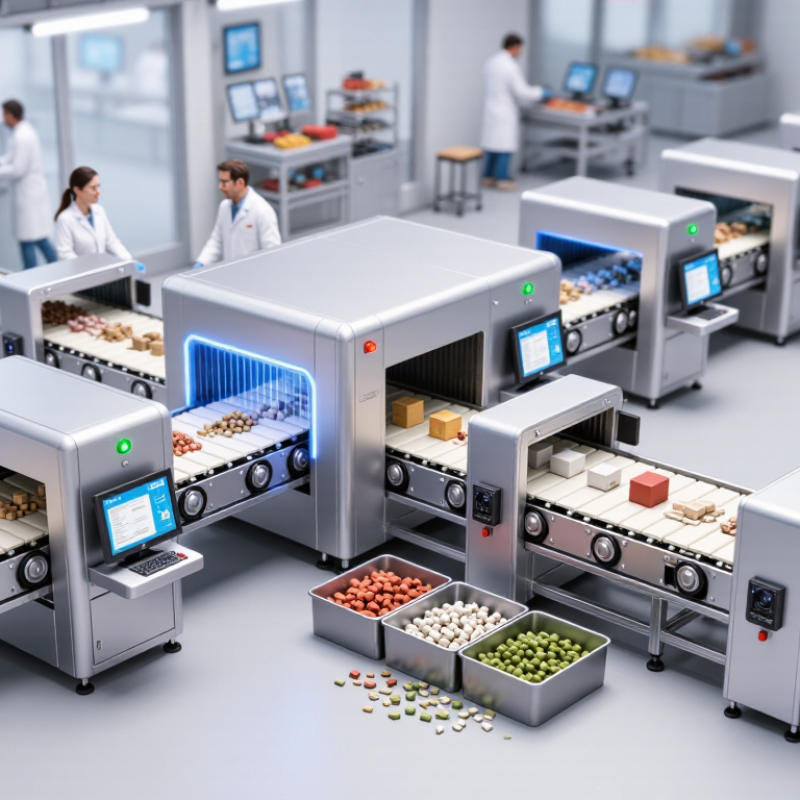
Table of Contents [Hide]
Assess Sorting Requirements and Material Characteristics
Choosing an optical sorter starts with the job, not the machine. Define what must be removed, what must be kept, and the required throughput per hour. Then describe the material: particle size, shape, moisture, surface texture, color variation, and how pieces overlap on the belt. A glossy red object may look different under wet conditions. Small differences matter. FAO’s 2023 report estimated that 13.2% of food was lost between harvest and retail in 2021. That figure is not a sorter performance benchmark, but it shows why careful handling and measurement matter.
Tips: Test representative batches, including dusty, wet, damaged, and unusually colored samples. Record false rejects and missed contaminants, not just overall accuracy. UNEP’s Food Waste Index Report 2024 estimated 1.05 billion tonnes of food waste in 2022 across retail, food service, and households. This is not all sortable material, so avoid treating the headline number as a sizing estimate. Use your own line data.
Check how material flows at actual operating speed. A clean lab sample can mislead; I would not trust one test run. Ask for results by material type and operating condition, then compare them with your acceptable loss rate and cleaning needs. If the target is unclear, pause before specifying sensors. It is an easy detail to overlook.