-
- Products
- Indoor Household Cords
- Appliance Cords
- General Purpose Short-Length Cords
- General Purpose Extension Cords
- Landscape & Decorating Cords
- Bright Color Extension Cords
- Oil-Resistant Extension Cords
- Cold-Flex Extension Cords
- VividFlex Power Cords
- EXTREME All-Weather Cords
- Cord Management
- Task Lights
- Adapters & GFCI Devices
- Where to Buy
- About
- Careers
- Glossary
- Catalog

How to Choose an MCB Assembly Robot in 2026?
Choosing an MCB Assembly Robot in 2026 requires more than comparing speed, price, and supplier brochures. The International Federation of Robotics reported 541,302 industrial robots installed worldwide in 2023, a 10% annual increase. Its World Robotics 2024 report also recorded more than 4.28 million robots operating globally. These figures show strong automation momentum, but they do not identify the right machine for every circuit-breaker factory.
MCB production demands stable feeding, accurate component placement, controlled screwdriving, electrical testing, and traceable quality records. A suitable robot should manage tiny terminals without damaging plastic housings. It should also recover safely from misalignment, jammed feeders, and missing parts. Jeff Burnstein, former president of the Association for Advancing Automation, has stated, “Robots are not taking jobs; they’re taking tasks.” That principle matters here. The best MCB Assembly Robot supports skilled technicians instead of treating human judgment as unnecessary.
Reports from IFR and market analyses from MarketsandMarkets indicate continued growth in industrial robotics and factory automation. Still, broad market growth can mislead buyers. An impressive cycle time may collapse when products change frequently. A cheaper system may create costly downtime later. Look closely at feeder accuracy, changeover time, vision inspection, maintenance access, software openness, and local service coverage. Safety compliance should be verified against applicable standards, including ISO 10218 and IEC 60204-1. No machine is perfect. A practical decision combines production evidence, supplier references, sample testing, and a realistic return-on-investment model. The right choice is not always the fastest robot. It is the one that remains dependable beside your operators, shift after shift.
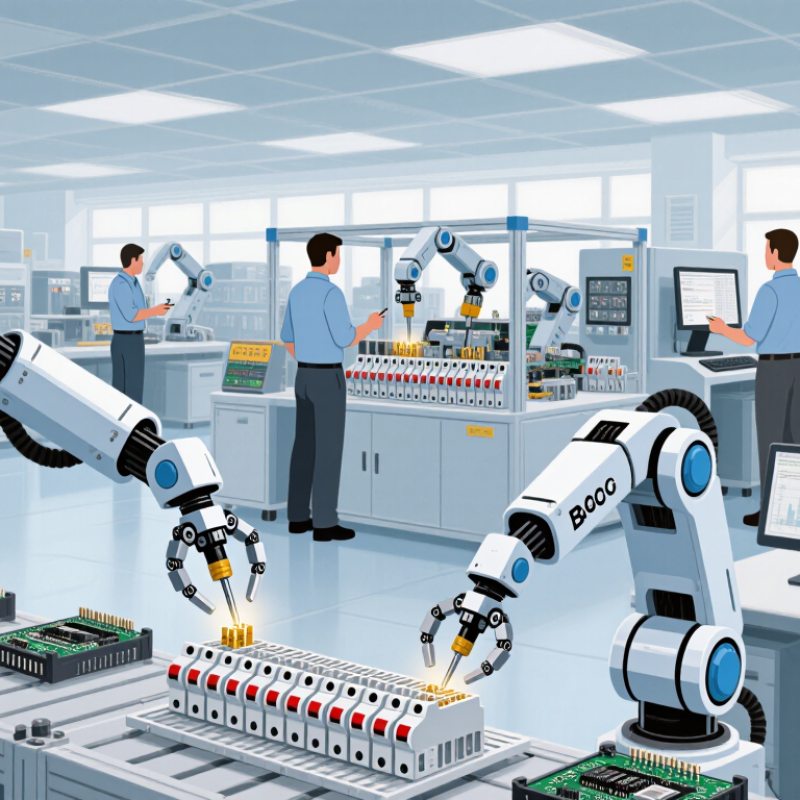
Table of Contents [Hide]
Define the MCB Assembly Requirements and Production Goals
Before choosing an MCB assembly robot in 2026, define the product range and daily output. Record pole configurations, rated current, housing dimensions, and component tolerances. A line making 6,000 units per shift needs different motion control than a pilot cell producing 500. Measure actual cycle time, not the figure on a quotation. Small delays matter.
Map every assembly step, from contact placement and spring insertion to screw fastening and electrical testing. Note where operators adjust parts, clear jams, or inspect alignment. These points reveal the required tooling, vision accuracy, gripping force, and changeover method. Set measurable goals for cycle time, first-pass yield, reject rate, traceability, and fault recovery. For example, target 98% first-pass yield with changeovers under 15 minutes. That target may be too optimistic. Validate it with real samples.
Define future needs before fixing the machine layout. Product variants may grow, while floor space and maintenance skills remain limited. Specify data interfaces, cleaning access, spare-part availability, and training hours. Request test runs using real breakers, packaging materials, and worst-case tolerances. Review the results with production, quality, and maintenance staff. Their disagreement is useful. It often exposes a requirement nobody documented.